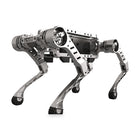
- Over 200 functional modules The robot is built from more than 200 functional modules, including 12 independent joints, an open perception head and an expansion dock, and every part can be removed, replaced or upgraded.
- Assembled without special tools Standardised modules with unified interfaces let a beginner take it from loose parts to a walking robot without specialist tools or skills.
- Open interfaces, shells and code You can write your own gaits and control logic, train motions with reinforcement learning and 3D-print new shells from MirrorMe's files.
- SDK, graphical programming and app control A motion-control SDK serves developers, graphical programming suits first lessons, and the app drives and customises the robot.
- Up to 4 m/s and 720° flips About 33 N·m of joint torque gives speeds up to 4 m/s, 20 cm climbs, 30° slopes and flips of up to 720°.
- About 1.5 hours per charge The 167 Wh battery at 28.8 V runs about 1.5 hours with no load; the Black Panther X Pro edition carries 418 Wh for about 4 hours.


Description
The MirrorMe Black Panther X (BPX) is a quadruped robot you build yourself. MirrorMe, the team behind the Black Panther II quadruped, designed it as more than 200 functional modules: 12 independent high-performance joints, an open perception head and an expansion dock that fit together through unified interfaces, with no special tools.
Once built it is a real robot dog. About 33 N·m of joint torque gives speeds up to 4 m/s, 20 cm climbs, 30° slopes and flips of up to 720°. It carries about 5 kg and runs about 1.5 hours per charge from a 167 Wh battery, weighs 15.1 kg and stands 660 × 370 × 480 mm.
Everything stays open after assembly. Students and developers can write their own gaits and control logic, train motions with reinforcement learning, mount third-party sensors and payloads, and 3D-print new shells from MirrorMe's files. A motion-control SDK, graphical programming and app control take a class from its first build to research projects.
The BPX is the entry edition. The Black Panther X Pro keeps the same build and adds a 418 Wh battery for about 4 hours, about 50 N·m joints and about 8 kg of payload.
Key Capabilities
- Modular build: Over 200 functional modules that can be removed, replaced and upgraded.
- Tool-free assembly: Standardised modules and unified interfaces, with MirrorMe's assembly manual and drawings.
- Open development: Motion-control SDK, graphical programming, app control and open code.
- Expandable: An expansion dock and open perception head for third-party sensors and payloads.
- Agile: Up to 4 m/s, 20 cm climbs, 30° slopes and 720° flips.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Official Product Videos
Features
Specs
| Brand | MirrorMe |
|---|---|
| Model | Black Panther X (BPX) |
| Robot type | Modular, build-it-yourself quadruped robot |
| Standing dimensions (L × W × H) | 660 × 370 × 480 mm |
| Crouching dimensions (L × W × H) | 790 × 370 × 190 mm |
| Weight (including battery) | 15.1 kg |
| Material | High-strength aluminium alloy and engineering plastics |
| Nominal voltage | 28.8 V |
| Battery | 167 Wh |
| Endurance (no load) | About 1.5 hours |
| Maximum payload | About 5 kg |
| Speed | 0–4 m/s |
| Maximum climbing height | About 20 cm |
| Maximum climbing angle | 30° |
| Maximum joint torque | About 33 N·m |
| Degrees of freedom | 12 |
| Side-swing joint range | −50° to 50° |
| Hip joint range | −149° to 45° |
| Knee joint range | 21° to 147° |
| Modules | Over 200 functional modules, including 12 independent joints, an open perception head and an expansion dock |
| Assembly | Standardised modules with unified interfaces, no special tools; MirrorMe assembly manual and drawings |
| Development | Motion-control SDK, graphical programming and app control; open interfaces, shells (3D files) and code |
| Expansion | Third-party sensors, cameras and payloads; autonomy with an added sensor set and external computer (e.g. NVIDIA Jetson Orin, Raspberry Pi) |
Compare the models
MirrorMe Black Panther X series
| This modelBlack Panther X | Black Panther X Pro | |
|---|---|---|
| Power and runtime | ||
| Battery | 167 Wh | 418 Wh |
| Endurance (no load) | 1.5 h | 4 h |
| Nominal voltage | 28.8 V | |
| Body | ||
| Standing (L × W × H) | 660 × 370 × 480 mm | 660 × 390 × 480 mm |
| Crouching (L × W × H) | 790 × 370 × 190 mm | 790 × 390 × 190 mm |
| Weight, with battery | 15.1 kg | 17.5 kg |
| Material | High-strength aluminium alloy and engineering plastics | |
| Motion | ||
| Max joint torque | About 33 N·m | About 50 N·m |
| Max payload | About 5 kg | About 8 kg |
| Speed | 0–4 m/s | |
| Max climbing height | About 20 cm | |
| Max climbing angle | 30° | |
| Degrees of freedom | 12: side swing, hip and knee on each leg | |
| Joint ranges | Side swing −50° to 50° · hip −149° to 45° · knee 21° to 147° | |
| Build and software, shared by both | ||
| Modules | Over 200 functional components: 12 independent joints, open perception head, expansion dock | |
| Assembly | Standardised modules and unified interfaces, no special tools · DIY kit or pre-assembled | |
| Programming | C++ and Python SDK · visual programming (Mind+ Python mode) · app control | |
| Models and training | URDF, MuJoCo and USD models for each edition · reinforcement learning in Isaac Lab | |
| Open design | Open interfaces, shells (3D files) and code · third-party sensors and payloads | |
| Control | Remote-controlled base; autonomy with added sensors and an external computer | |
Industries
Product Brochure

MirrorMe Black Panther X Modular Quadruped Robot – Product Brochure
The Robotix Market brochure with every capability and the full technical specification — to save, print or forward.
Download Brochure (PDF)Frequently Asked Questions
The MirrorMe Black Panther X Modular Quadruped Robot is priced at €6.425 in your market. For classroom sets or project orders, contact us for a business quote.
Both have the same 12-joint modular build, top speed of 4 m/s, 20 cm climbs and 30° slopes. The Black Panther X Pro carries a 418 Wh battery for about 4 hours instead of 167 Wh and 1.5 hours, about 50 N·m joints instead of 33 N·m and about 8 kg of payload instead of 5 kg. It weighs 17.5 kg against 15.1 kg and is 390 mm wide instead of 370 mm.
MirrorMe designs the Black Panther X to be built by its owner: standardised modules with unified interfaces go together without special tools, following MirrorMe's assembly manual and drawings. MirrorMe also offers it pre-assembled; whether your unit ships as a kit or assembled is confirmed with your order.
Yes. Interfaces, shells and code are open. There is a motion-control SDK, graphical programming and custom control through the app, and you can define your own gaits and control logic or train motions with reinforcement learning.
The base robot is remote-controlled. As an open platform it takes third-party sensors and payloads, so teams add a camera or LiDAR and an external computer such as an NVIDIA Jetson Orin or a Raspberry Pi to build autonomous behaviour.
About 1.5 hours with no load, from a 167 Wh battery at 28.8 V; load and fast running shorten it. If runtime matters most, the Black Panther X Pro runs about 4 hours.
Recently Viewed
You haven't viewed any products yet.