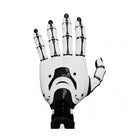
- Bionic tendon drive Cables carry the motor force through the hand to the joints, keeping the fingers slim and light and letting them give on contact with an object.
- 17 active joints Seventeen motor-driven joints and four passive ones, 21 in all, give it one more active joint than the L20 Pro.
- Optional fingertip tactile matrix Pressure-matrix sensors can be fitted to the fingertips, and Linkerbot's GUI shows their readings as a heat map and a waveform.
- CAN FD at 500 kbps The hand runs on a DC 24 V supply and connects over CAN FD through a USB-to-CAN FD adapter.
- ROS 2 SDK and GUI Linkerbot's L30 ROS 2 SDK for Ubuntu drives left and right hands, sets finger speeds and includes preset gestures.
- 5 kg load, 12 N grip The hand carries up to 5 kg and grips with 12 N, sized for precise, human-like handling rather than heavy lifting.

Description
The Linkerbot Linker Hand L30 Cable-Driven is a tendon-driven five-finger dexterous robotic hand: cables carry the force from its motors to the finger joints, the way tendons work in a human hand. It has 21 joints, 17 of them active and 4 passive, weighs about 1,400 g and is made as a left or a right hand.
Routing the drive through cables keeps the fingers slim and light and lets them give slightly on contact, which is why tendon hands are chosen for human-like, contact-rich manipulation rather than heavy lifting. The L30 carries up to 5 kg and grips with 12 N. It suits humanoid robot developers and research groups working on biomimetic grasping, in-hand repositioning, tool use and teleoperation, where the number of actively controlled joints matters most.
Control runs over CAN FD at 500 kbps through a USB-to-CAN FD adapter, on a DC 24 V supply. Linkerbot's L30 ROS 2 SDK for Ubuntu drives one hand or a pair, sets finger speeds and comes with a GUI of preset gestures. Fingertip pressure-matrix sensors are optional; when they are fitted, the SDK publishes the tactile data and the GUI shows each fingertip as a heat map.
Compare it with the Linker Hand L20 Pro, which drives 16 joints through linkages for a 100 N grip, and the six-finger Linker Hand J42, also tendon-driven. The full range is in our dexterous robotic hands.
Key Capabilities
- Bionic tendon drive: Cables carry the motor force through the hand to the joints, keeping the fingers slim and light and letting them give on contact with an object.
- 17 active joints: Seventeen motor-driven joints and four passive ones, 21 in all, give it one more active joint than the L20 Pro.
- Optional fingertip tactile matrix: Pressure-matrix sensors can be fitted to the fingertips, and Linkerbot's GUI shows their readings as a heat map and a waveform.
- CAN FD at 500 kbps: The hand runs on a DC 24 V supply and connects over CAN FD through a USB-to-CAN FD adapter.
- ROS 2 SDK and GUI: Linkerbot's L30 ROS 2 SDK for Ubuntu drives left and right hands, sets finger speeds and includes preset gestures.
- 5 kg load, 12 N grip: The hand carries up to 5 kg and grips with 12 N, sized for precise, human-like handling rather than heavy lifting.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Linkerbot |
|---|---|
| Model | Linker Hand L30 |
| Version | Cable-driven (tendon) |
| Fingers | 5 |
| Degrees of freedom | 17 active + 4 passive (21 joints) |
| Transmission | Tendon (cable) drive |
| Weight | About 1,400 g |
| Maximum load | 5 kg |
| Grip force | 12 N |
| Control interface | CAN FD, 500 kbps |
| Adapter | USB-to-CAN FD |
| Operating voltage | DC 24 V |
| Tactile sensing | Optional fingertip pressure-matrix sensors |
| Software | Linkerbot L30 ROS 2 SDK for Ubuntu; GUI with preset gestures, finger-speed setting and tactile heat map |
| Hand side | Left and right versions |
| Repeatability | Confirm at quote |
| Dimensions | Confirm at quote |
| Robot mounting | Confirm at quote |
Industries
Frequently Asked Questions
The Linkerbot Linker Hand L30 Cable-Driven Dexterous Hand is priced at €22.650 in your market.
Tendons (cables) carry the force from the motors to the finger joints, as tendons do in a human hand. The fingers stay slim and light and give slightly on contact, which suits delicate, human-like manipulation.
Twenty-one joints: 17 active joints driven by motors and 4 passive joints.
Fingertip pressure-matrix sensors are optional. Linkerbot's ROS 2 SDK publishes their data, and its GUI shows each fingertip as a heat map and a waveform.
Over CAN FD at 500 kbps through a USB-to-CAN FD adapter, on a DC 24 V supply. Linkerbot's ROS 2 SDK for Ubuntu drives the hand, and it is made in left and right versions, so two make a pair.
The L20 Pro moves 16 active joints through linkages and ball screws, grips with 100 N and carries 20 kg. The L30 uses tendons for 17 active joints and a more human-like motion, carries 5 kg and weighs about 1,400 g.
Recently Viewed
You haven't viewed any products yet.