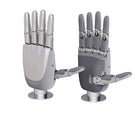
- 11 degrees of freedom at human scale Six active and five passive joints work together in a five-finger hand built to 1:1 human-hand proportion.
- Over 25 kg static lifting load The hand holds more than 10 kg in a vertical grip and over 25 kg in a flat grip or lift, with more than 10 N at each fingertip.
- 14 N pinch, 25 N side pinch Pinch and lateral pinch reach 14 N and 25 N, and the grip spans objects from 16 to 95 mm across.
- ±0.1 mm, over a million cycles Fingertips repeat to ±0.1 mm, and Casbot rates the hand for more than 1,000,000 fault-free continuous cycles.
- Three industrial buses RS-485, CAN FD and EtherCAT run on a 24–60 V supply, and the hand draws 80 mA at rest.
- Web setup, ROS 2 support The hand is configured from a web page without host software, carries preset commands and works with Windows, Linux, macOS and ROS 2.


Description
The Casbot Handle L1 is Casbot's lightweight, highly integrated five-finger dexterous robotic hand, built at 1:1 human-hand proportion for humanoid robots, robot arms and teleoperation systems. This is the standard version, without fingertip tactile sensors. It has 11 degrees of freedom, six of them active, weighs about 610 g and measures 194 × 84 × 52 mm.
Casbot built it for strength and endurance. Each of the four fingertips pushes with more than 10 N, pinch and lateral pinch reach 14 N and 25 N, and the hand holds more than 10 kg in a vertical grip and over 25 kg in a flat grip or lift. Adaptive force control lets the same hand pick up fragile, soft and irregular items, from eggs, tofu and potato chips to tissues and business cards, across grip diameters of 16 to 95 mm. Casbot rates it for more than 1,000,000 fault-free continuous cycles, with ±0.1 mm fingertip repeatability and resistance to accidental impacts and drops.
Integration is quick: the hand uses an open interface protocol over RS-485, CAN FD or EtherCAT on a 24–60 V supply, works with Windows, Linux, macOS and ROS 2, and is configured from a web page without host software. Built-in preset commands for grasping, pinching, pointing, pressing, hooking and lifting help it adapt quickly to robot arms and teleoperation systems. That makes it a fit for research and teaching labs, light production tasks such as moving material and pressing buttons, and service robots that shake hands or point the way.
The Casbot Handle L1 Pro is the same hand with tactile fingertips, measuring 0.15–20 N at 0.1 N resolution with a response within 5 ms, for grasping that relies on contact data. Compare both with the rest of our dexterous robotic hands.
Key Capabilities
- 11 degrees of freedom at human scale: Six active and five passive joints work together in a five-finger hand built to 1:1 human-hand proportion.
- Over 25 kg static lifting load: The hand holds more than 10 kg in a vertical grip and over 25 kg in a flat grip or lift, with more than 10 N at each fingertip.
- 14 N pinch, 25 N side pinch: Pinch and lateral pinch reach 14 N and 25 N, and the grip spans objects from 16 to 95 mm across.
- ±0.1 mm, over a million cycles: Fingertips repeat to ±0.1 mm, and Casbot rates the hand for more than 1,000,000 fault-free continuous cycles.
- Three industrial buses: RS-485, CAN FD and EtherCAT run on a 24–60 V supply, and the hand draws 80 mA at rest.
- Web setup, ROS 2 support: The hand is configured from a web page without host software, carries preset commands and works with Windows, Linux, macOS and ROS 2.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | Casbot |
|---|---|
| Model | Handle L1 (standard version) |
| Fingers | 5, at 1:1 human-hand proportion |
| Degrees of freedom | 11 (6 active, 5 passive) |
| Weight | About 610 g |
| Size | 194 × 84 × 52 mm |
| Four-finger fingertip force | > 10 N |
| Pinch / lateral pinch force | 14 N / 25 N |
| Static vertical grip load | > 10 kg |
| Static flat-grip and lifting load | > 25 kg |
| Grip diameter | 16–95 mm |
| Fingertip repeat positioning accuracy | ±0.1 mm |
| Repeated opening and closing | < 0.6 s |
| Control | Position closed loop and force-position closed loop; adaptive force control |
| Service life | Over 1,000,000 fault-free continuous cycles |
| Durability | Resists accidental impacts and drops |
| Tactile sensors | None (fitted on the Handle L1 Pro) |
| Communication interfaces | RS-485, CAN FD, EtherCAT |
| Software compatibility | Windows, Linux, macOS, ROS 2 |
| Configuration | Web-page setup without host software; built-in preset commands; open interface protocol |
| Operating voltage | 24–60 V |
| Current | 80 mA static, 350 mA with no load |
| Hand side | Confirm at quote |
| Robot mounting | Confirm at quote |
Industries
Frequently Asked Questions
The Casbot Handle L1 Dexterous Hand is priced at €3.540 in your market.
Eleven: six active and five passive joints, coordinated across five fingers at 1:1 human-hand proportion.
About 610 g. It holds more than 10 kg in a vertical grip and over 25 kg in a flat grip or lift, with more than 10 N at each fingertip and 14 N of pinch force.
Over RS-485, CAN FD or EtherCAT on a 24–60 V supply. It works with Windows, Linux, macOS and ROS 2 and is configured from a web page; mounting to your arm is confirmed with the quotation.
No, the standard Handle L1 controls its grip through position and force-position closed loops. The Handle L1 Pro adds fingertip tactile sensing from 0.15 to 20 N at 0.1 N resolution.
Casbot rates it for more than 1,000,000 fault-free continuous cycles and builds it to withstand accidental impacts and drops, with ±0.1 mm fingertip repeatability.
Recently Viewed
You haven't viewed any products yet.