- 3-axis force in every fingertip Each fingertip senses force in three axes and the palm in one, with more than 150 tactile points read at 0.01 N resolution across a 0–50 N range.
- 19 degrees of freedom, 12 driven Twelve motors move 19 joints through a linkage and screw-rod drive, so the four fingers spread ±10° and the thumb rotates 50° as well as flexing.
- 20 N at the fingertip Fingertips push with up to 20 N, and holding a 5 cm rigid object the hand carries 35 kg palm up and 5 kg palm down.
- 0.02 mm repositioning Fingers return to position within 0.02 mm and close on objects as small as 2 mm, which suits precise pinches and small parts.
- Five control modes Speed, position, force, hybrid position-force and tactile modes run over CAN FD at 1 kHz, with joint position, speed, torque, temperature, current and tactile pressure fed back.
- C++, Python and ROS 2 AgiBot's SDK offers C++ and Python APIs with a kinematics library and a ROS 2 interface on Linux, and it runs on Windows as well.


Description
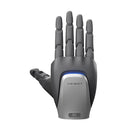
The AgiBot OmniHand Pro 2025 is the high-end dexterous robotic hand of AgiBot's OmniHand 2025 range, built around force sensing in every fingertip. Its five fingers have 19 degrees of freedom, 12 of them driven by their own motors through a linkage and screw-rod transmission, inside a PA and silicone body that measures 207 × 98 × 56 mm and weighs no more than 750 g. AgiBot builds it as a left and a right hand, so state the side, or a pair, with your order.
What sets the Pro apart is what it feels. Each fingertip measures force in three axes and the palm in one, across more than 150 tactile points with 0.01 N resolution and a 0–50 N range, and the sensors withstand 1,000 N without damage. A tactile control mode joins speed, position, force and hybrid position-force control, so a grasp can be set by contact rather than by joint angle alone. That makes it a fit for manipulation and grasp-learning research, teleoperation, and humanoids or arms that handle fragile, small or mixed objects.
It is also strong for its size: up to 20 N at each fingertip, and holding a 5 cm rigid object it carries 35 kg palm up and 5 kg palm down. Fingers reposition to 0.02 mm, close on objects from 2 mm across and close fully in 0.8 s. Control and data run over CAN FD at 1 kHz on a 12–24 V supply, and AgiBot's SDK gives C++ and Python APIs, a kinematics library and a ROS 2 interface on Linux, with Windows host software for setup. The CAN FD and power cables come in the box.
Within the OmniHand family, the OmniHand 2025 Tactile right hand is the lighter interactive model, with 16 degrees of freedom (10 active), one-axis touch sensing that also covers the back of the hand, and RS-485 alongside CAN FD. The OmniHand 3 Ultra-M is AgiBot's direct-drive flagship with 21 active degrees of freedom and vision-based tactile fingertips. Compare them with the rest of our dexterous robotic hands.
Key Capabilities
- 3-axis force in every fingertip: Each fingertip senses force in three axes and the palm in one, with more than 150 tactile points read at 0.01 N resolution across a 0–50 N range.
- 19 degrees of freedom, 12 driven: Twelve motors move 19 joints through a linkage and screw-rod drive, so the four fingers spread ±10° and the thumb rotates 50° as well as flexing.
- 20 N at the fingertip: Fingertips push with up to 20 N, and holding a 5 cm rigid object the hand carries 35 kg palm up and 5 kg palm down.
- 0.02 mm repositioning: Fingers return to position within 0.02 mm and close on objects as small as 2 mm, which suits precise pinches and small parts.
- Five control modes: Speed, position, force, hybrid position-force and tactile modes run over CAN FD at 1 kHz, with joint position, speed, torque, temperature, current and tactile pressure fed back.
- C++, Python and ROS 2: AgiBot's SDK offers C++ and Python APIs with a kinematics library and a ROS 2 interface on Linux, and it runs on Windows as well.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Official Product Videos
Features
Specs
| Brand | AgiBot |
|---|---|
| Model | OmniHand Pro 2025 (O12) |
| Hand side | Left or right; state the side, or a pair, with your order |
| Fingers | 5 |
| Degrees of freedom | 19 (12 active) |
| Joints | 19 |
| Transmission | Linkage, driven by motor and screw rod |
| Material | PA and silicone |
| Weight | ≤ 750 g |
| Size | 207 × 98 × 56 mm |
| Joint ranges | Four-finger flexion 80°, four-finger abduction/adduction ±10°, thumb flexion 50°, thumb abduction/adduction 90°, thumb rotation 50° |
| Minimum closing time | 0.8 s (typical) |
| Minimum grasp diameter | 2 mm |
| Finger repositioning accuracy | 0.02 mm (typical) |
| Maximum fingertip force | 20 N (typical) |
| Load capacity, palm up | 35 kg (5 cm rigid object) |
| Load capacity, palm down | 5 kg (5 cm rigid object) |
| Tactile sensing | 3-axis force sensing in the fingertips, 1-axis force sensing in the palm, more than 150 tactile points |
| Sensing resolution | 0.01 N |
| Sensing range | 0–50 N |
| Maximum non-destructive force | 1,000 N |
| Communication interface | CAN FD |
| Communication rate | 1 kHz (48-byte data packets) |
| Feedback | Joint position, speed, torque and temperature; current; tactile pressure |
| Control modes | Speed, position, force, hybrid position-force and tactile |
| Operating voltage | 12–24 V |
| Current | 0.5 A idle, 4.5 A maximum |
| Operating temperature | −20 to 50 °C |
| SDK | C++ and Python APIs with a kinematics library; ROS 2 interface on Linux; Linux (x64, arm64) and Windows (x64) |
| Host software | Windows |
| What's in the box | OmniHand Pro 2025, CAN FD communication cable, power cable, certificate of conformity |
| Robot mounting | Confirm at quote |
Industries
Frequently Asked Questions
The AgiBot OmniHand Pro 2025 Dexterous Hand is priced at €3.020 in your market.
Nineteen across 19 joints, 12 of them motor-driven. The four fingers flex 80° and spread ±10°, and the thumb flexes 50°, abducts 90° and rotates 50°.
Three-axis force sensing in each fingertip and one-axis force sensing in the palm, with more than 150 tactile points. Resolution is 0.01 N over a 0–50 N range, and a tactile control mode uses the data directly.
It weighs no more than 750 g. Each fingertip pushes with up to 20 N, and holding a 5 cm rigid object the hand carries 35 kg palm up and 5 kg palm down.
Over CAN FD at 1 kHz, on a 12–24 V supply. AgiBot's SDK provides C++ and Python APIs and a ROS 2 interface on Linux, with Windows support; AgiBot builds left and right hands, and mounting to your arm or humanoid is confirmed with the quotation.
The Pro has 19 degrees of freedom (12 active) against 16 (10 active), three-axis fingertip force sensing at 0.01 N, and 20 N fingertips against 5 N. The OmniHand 2025 is lighter at about 510 g, adds RS-485 and USB, and its Tactile build also senses touch on the back of the hand.
Recently Viewed
You haven't viewed any products yet.